 Inverse kinematics
Common
Rarity: Common
The most frequent rarity: most Wikipedia articles become Commons.
Rarity follows how well known the article is: its views on the French and English Wikipedia over a year, and the number of languages it exists in.
At a glance
- Class
- Notion
- Domain
- Science and technology
- In collections
- Nobody has pulled it yet.
What Wikipedia says
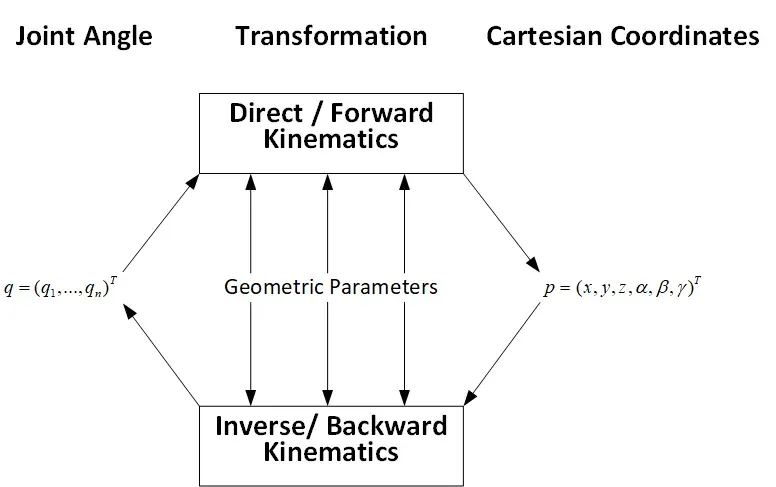
In computer animation and robotics, inverse kinematics (IK) is the mathematical process of calculating the variable joint parameters needed to place the end of a kinematic chain, such as a robot manipulator or an animation rig's hand or foot, in a given position and orientation (relative to the start of the chain).
Excerpt from the Wikipedia article “Inverse kinematics”, under the CC BY-SA 4.0 license. Read the article on Wikipedia
Image: Haendy-freak, CC BY-SA 4.0, via Wikimedia Commons.
Open free boosters and add Inverse kinematics to your collection.
Play for free